 Google Scholar
Efficient Model-Based RL
Telluride Neuromorphic Workshop 2025 (Project Leader)
(Work in Progress)
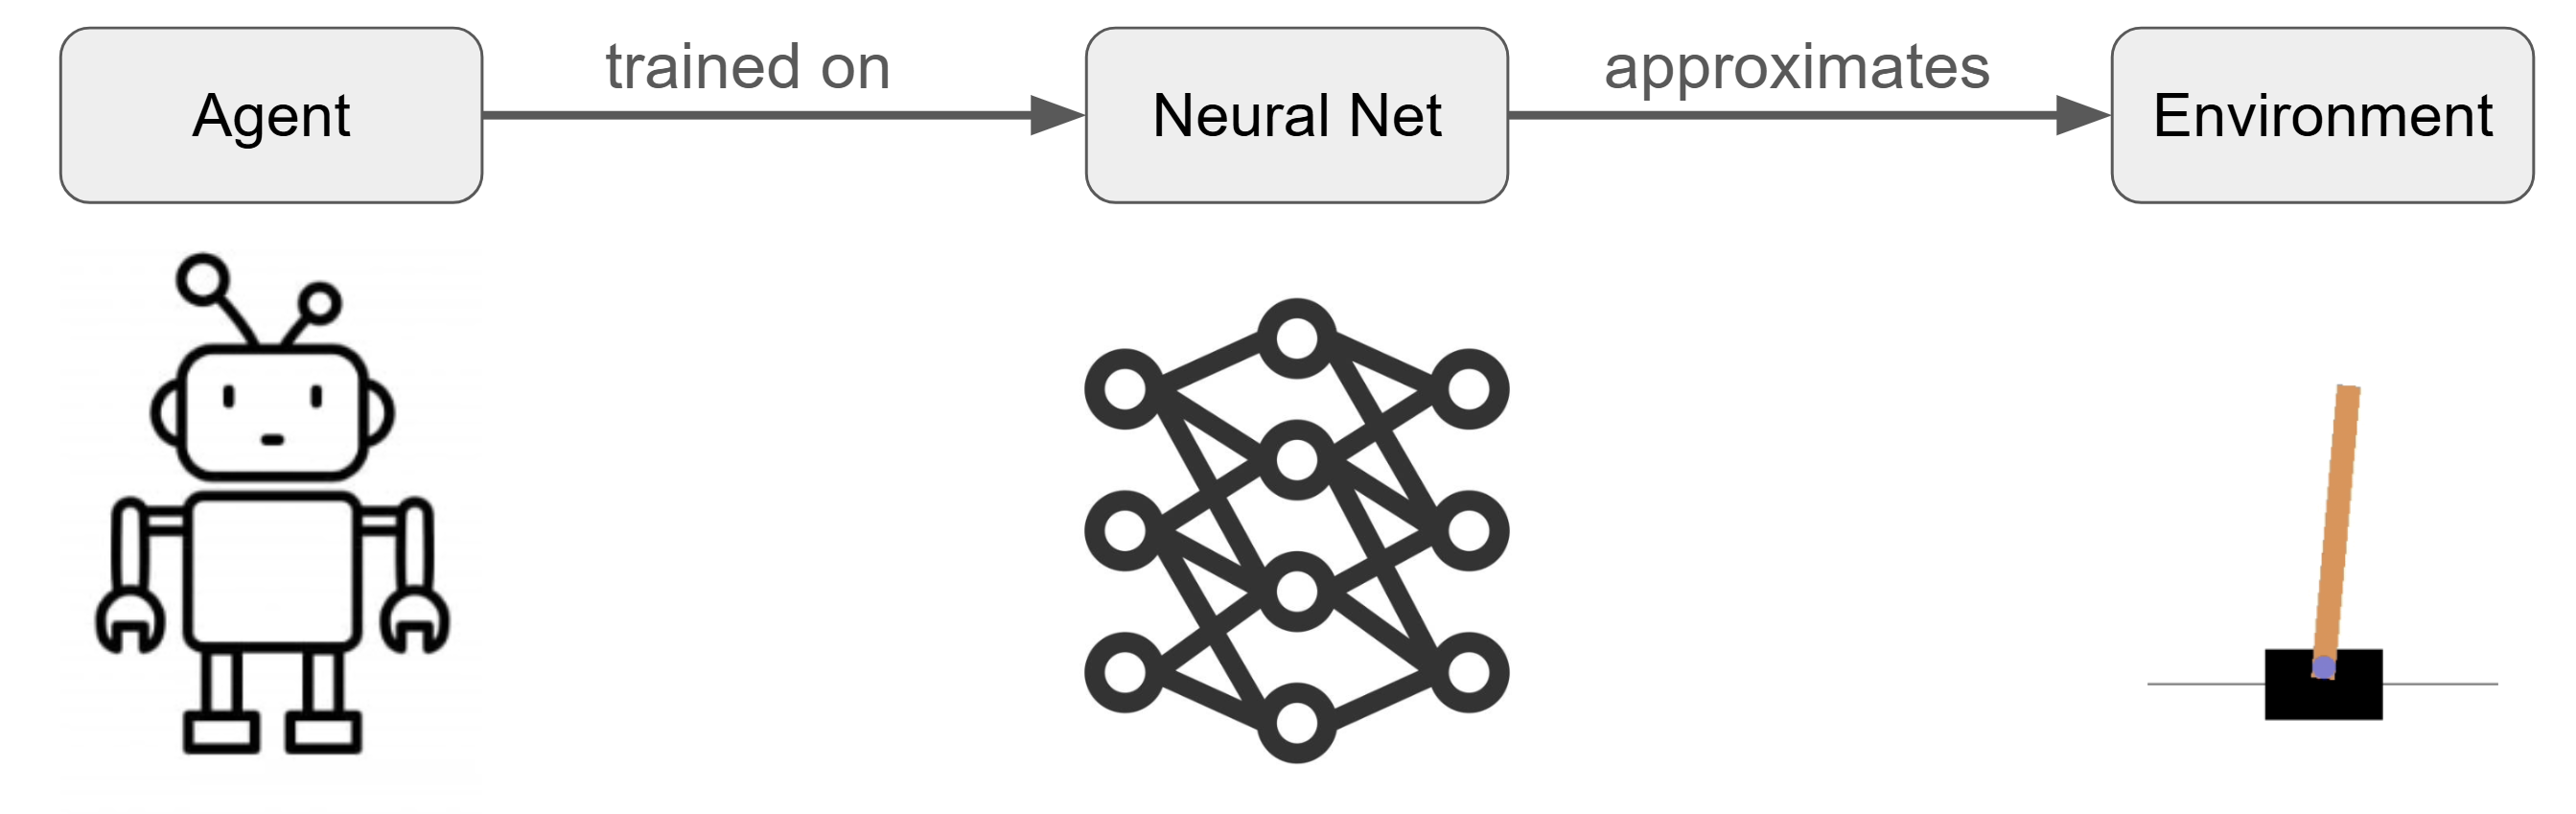
This project implements a model-based reinforcement learning (MBRL) framework that uses a Gated Recurrent Unit (GRU)-based recurrent neural network to approximate environment dynamics. The system operates in a closed loop, where a world model is continuously updated from collected experience data while an agent trains within the simulated environment. This approach, demonstrated on the CartPole swing-up task, enables agent training through internal simulation for improved sample efficiency.
The framework is designed as a foundation for developing future MBRL systems on neuromorphic and embedded hardware for real-world applications. The final goal is to enable computational efficiency for Model-based RL algorithms.
Results
The following visualizations demonstrate the core components of the trained system.
1. World Model Prediction
The animation below shows the world model’s prediction of the CartPole’s next states and rewards based on a given actions, overlaid with the actual outcome from the environment.
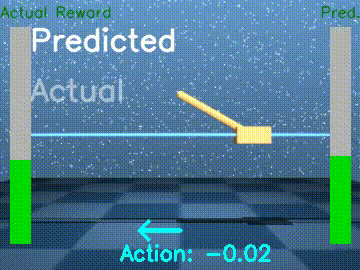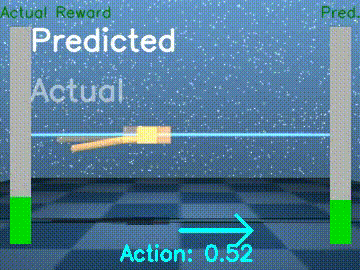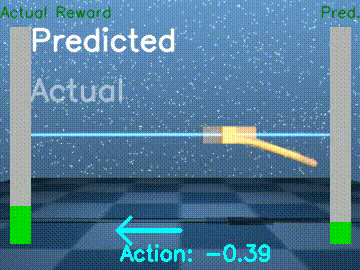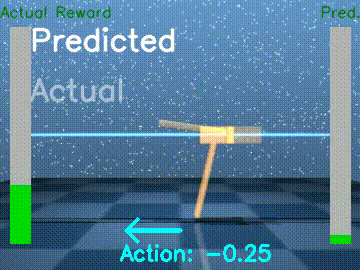
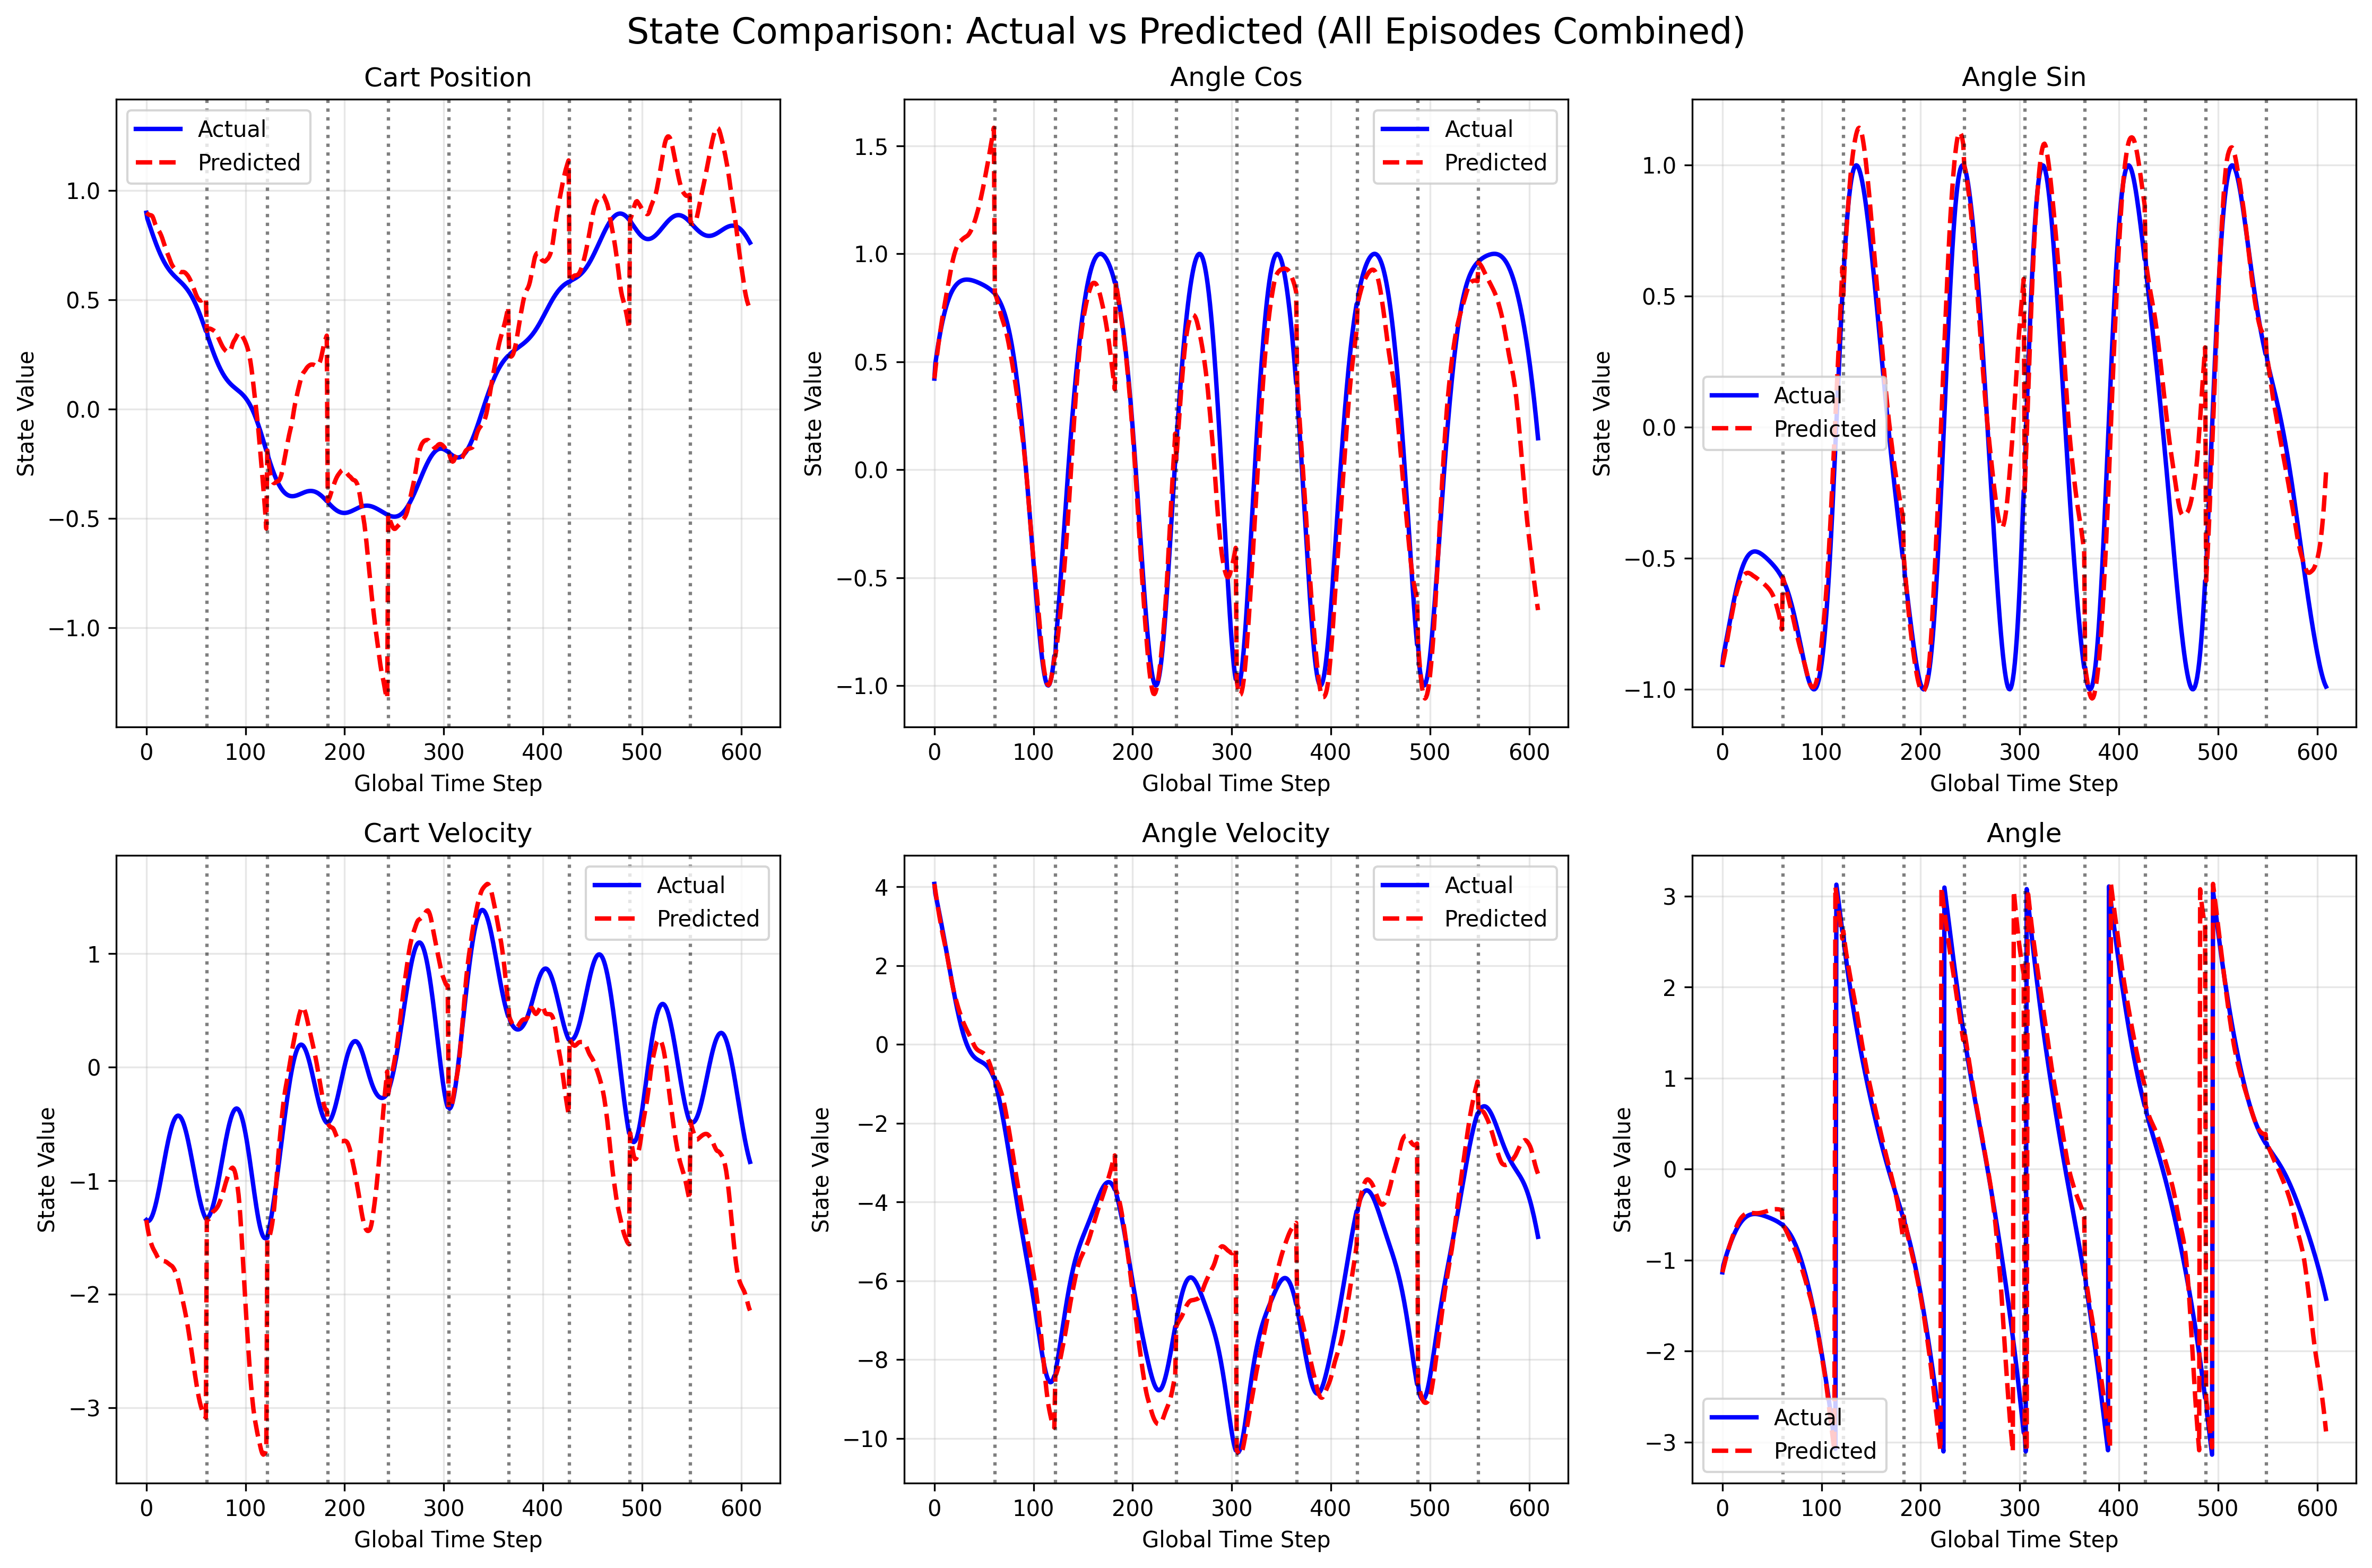
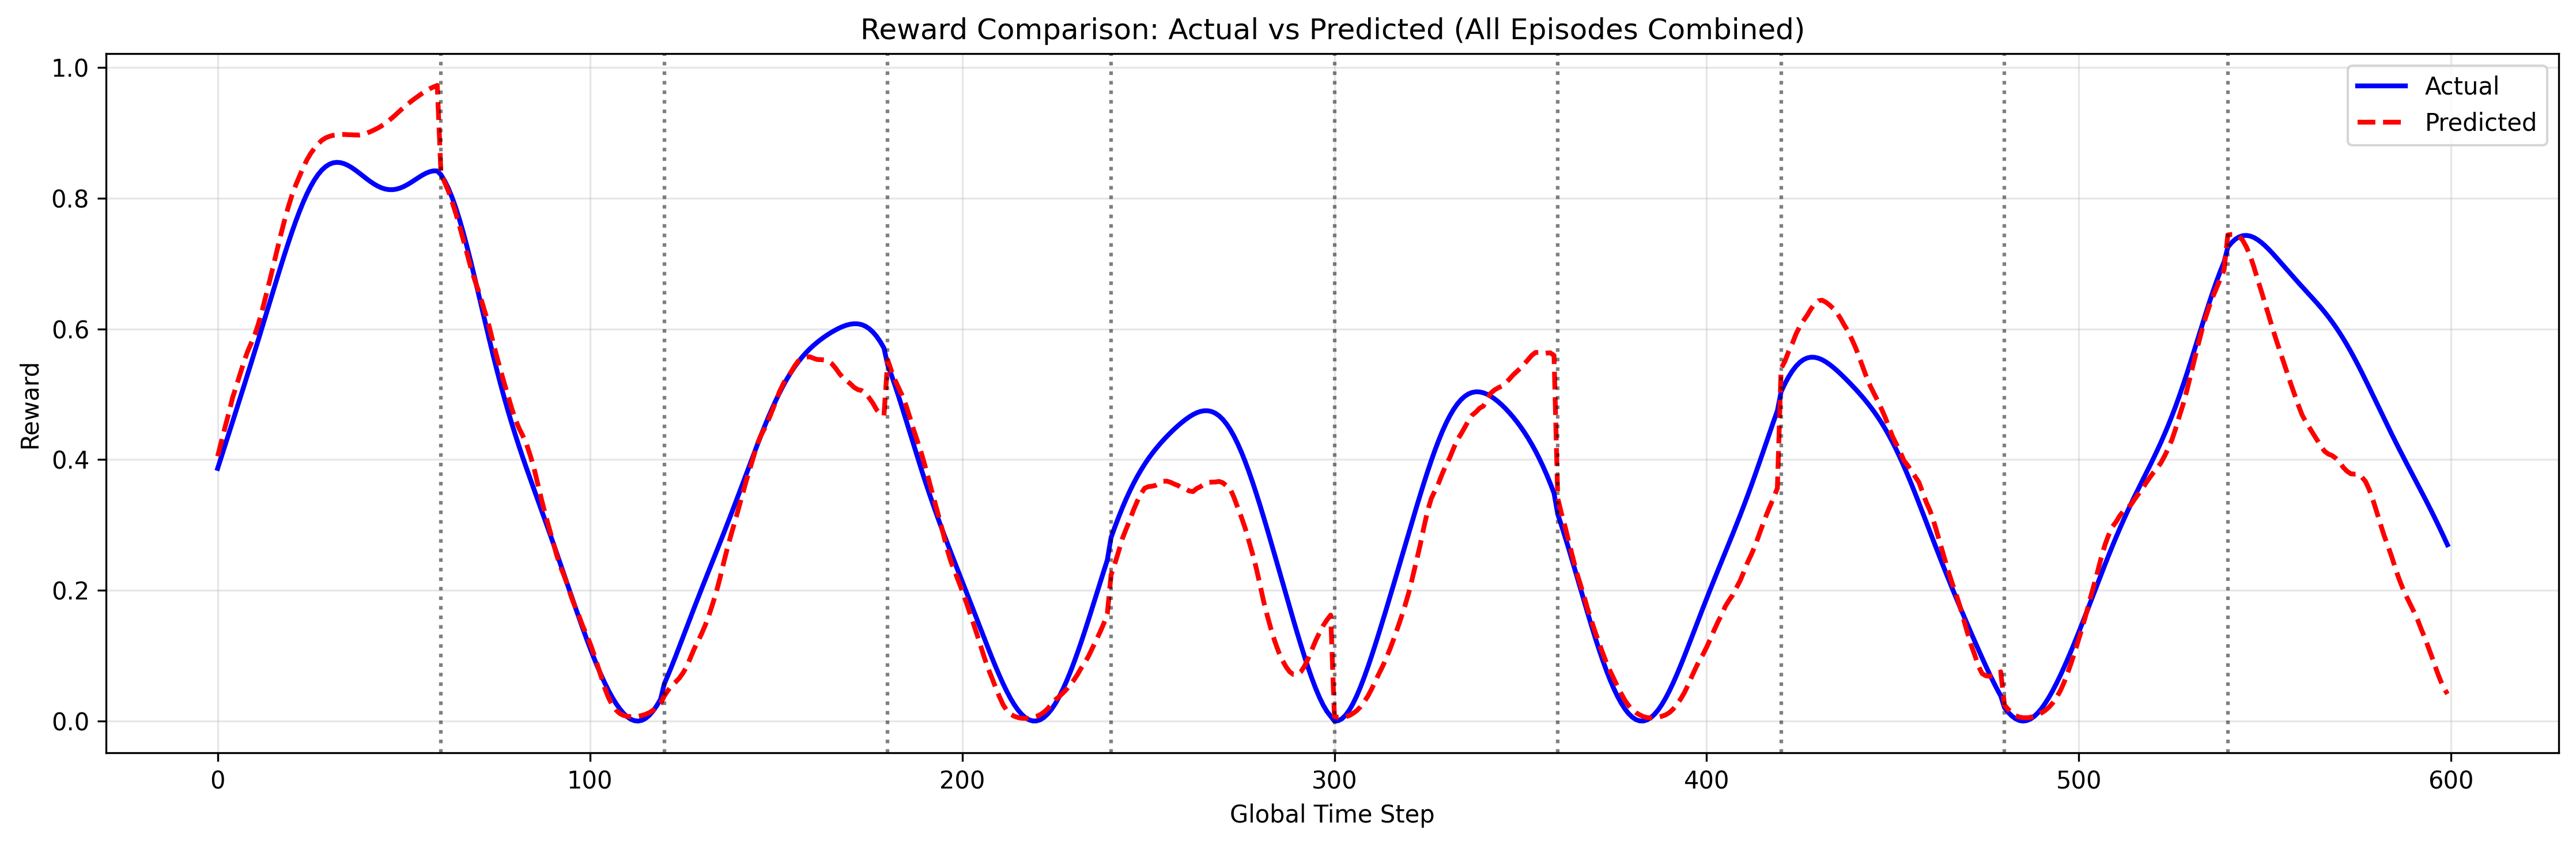
The plots below provide a more detailed view of the world model’s accuracy, comparing the predicted values against the actual values for each state variable and the reward over a sequence of steps.
2. Trained Agent Performance
This animation shows the final agent, trained entirely within the world model’s “imagination,” successfully performing the CartPole swing-up and balancing task in the real environment.